
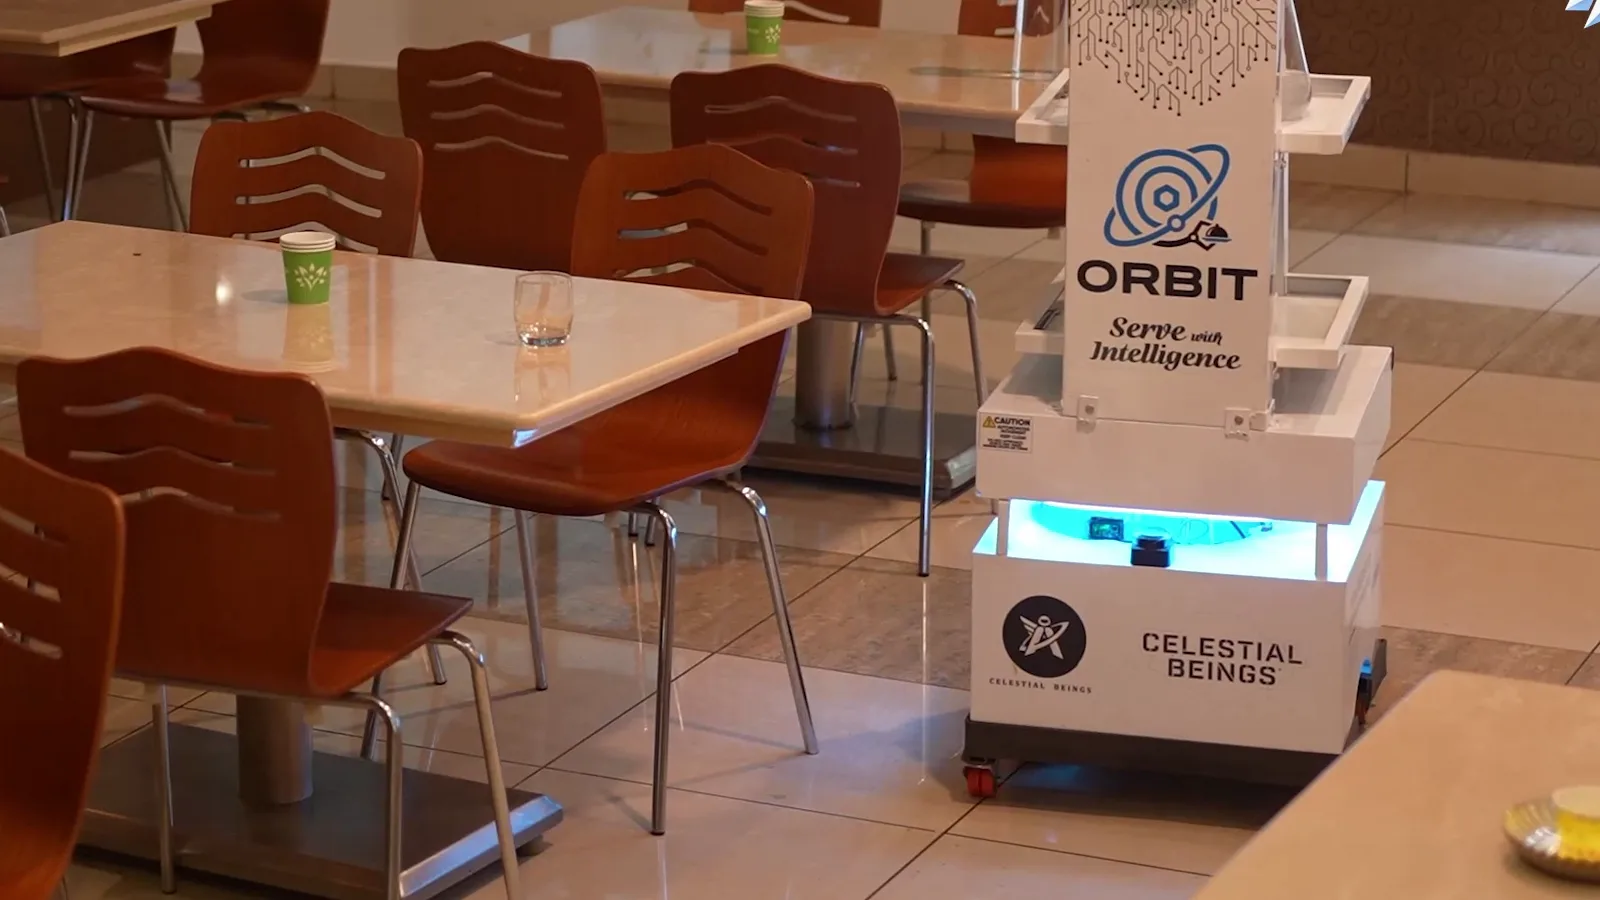
ORBIT in a live dining environment
ORBIT moving through a working dining hall, carrying orders from the service counter to guests' tables.
PProjects & Technology
Demonstrations, prototypes and programmes across autonomous mobility, perception, software, education and environmental robotics.
ORBIT moving through a working dining hall, carrying orders from the service counter to guests' tables.
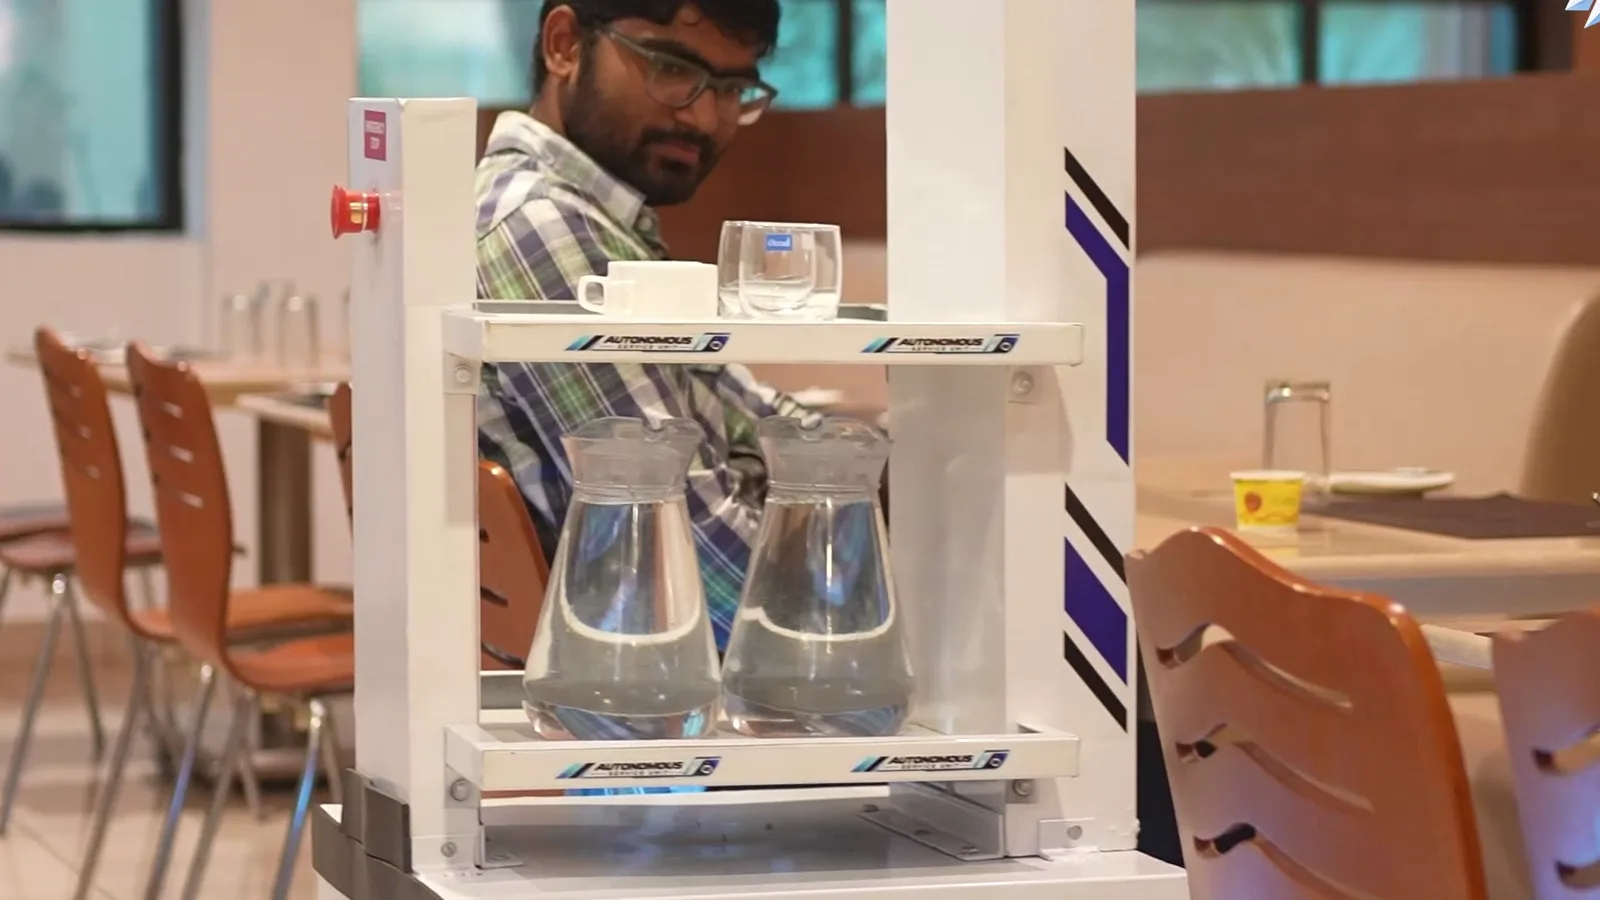
Guests collect drinks and dishes directly from ORBIT's open trays — designed for a natural, low-friction hand-off.
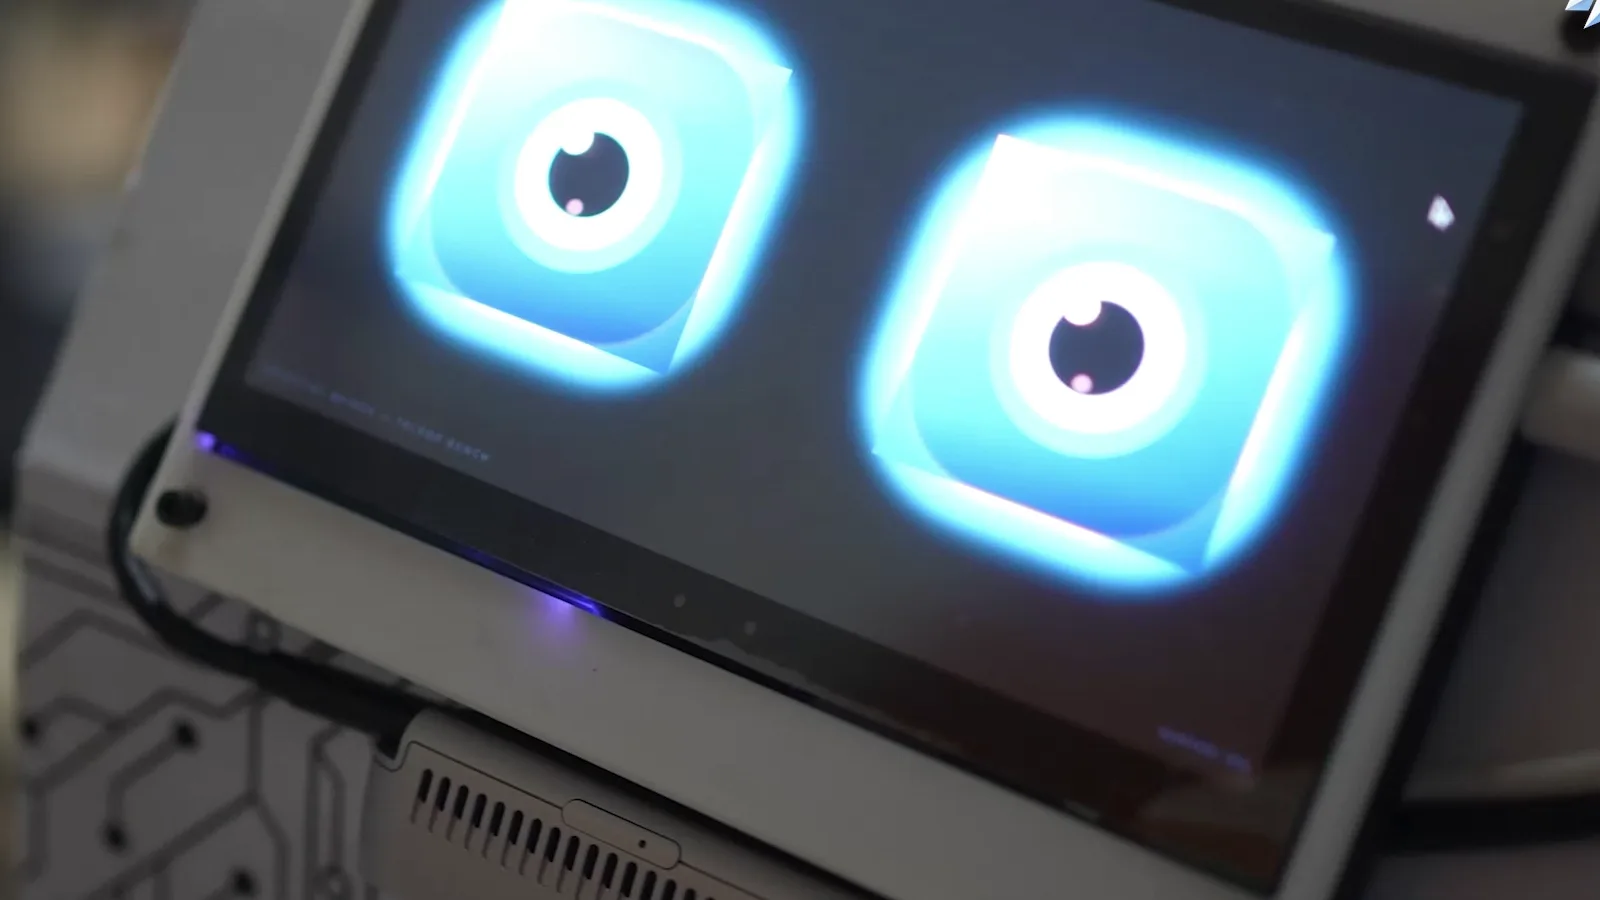
A touchscreen face gives the robot a readable, friendly presence and a surface for interaction.
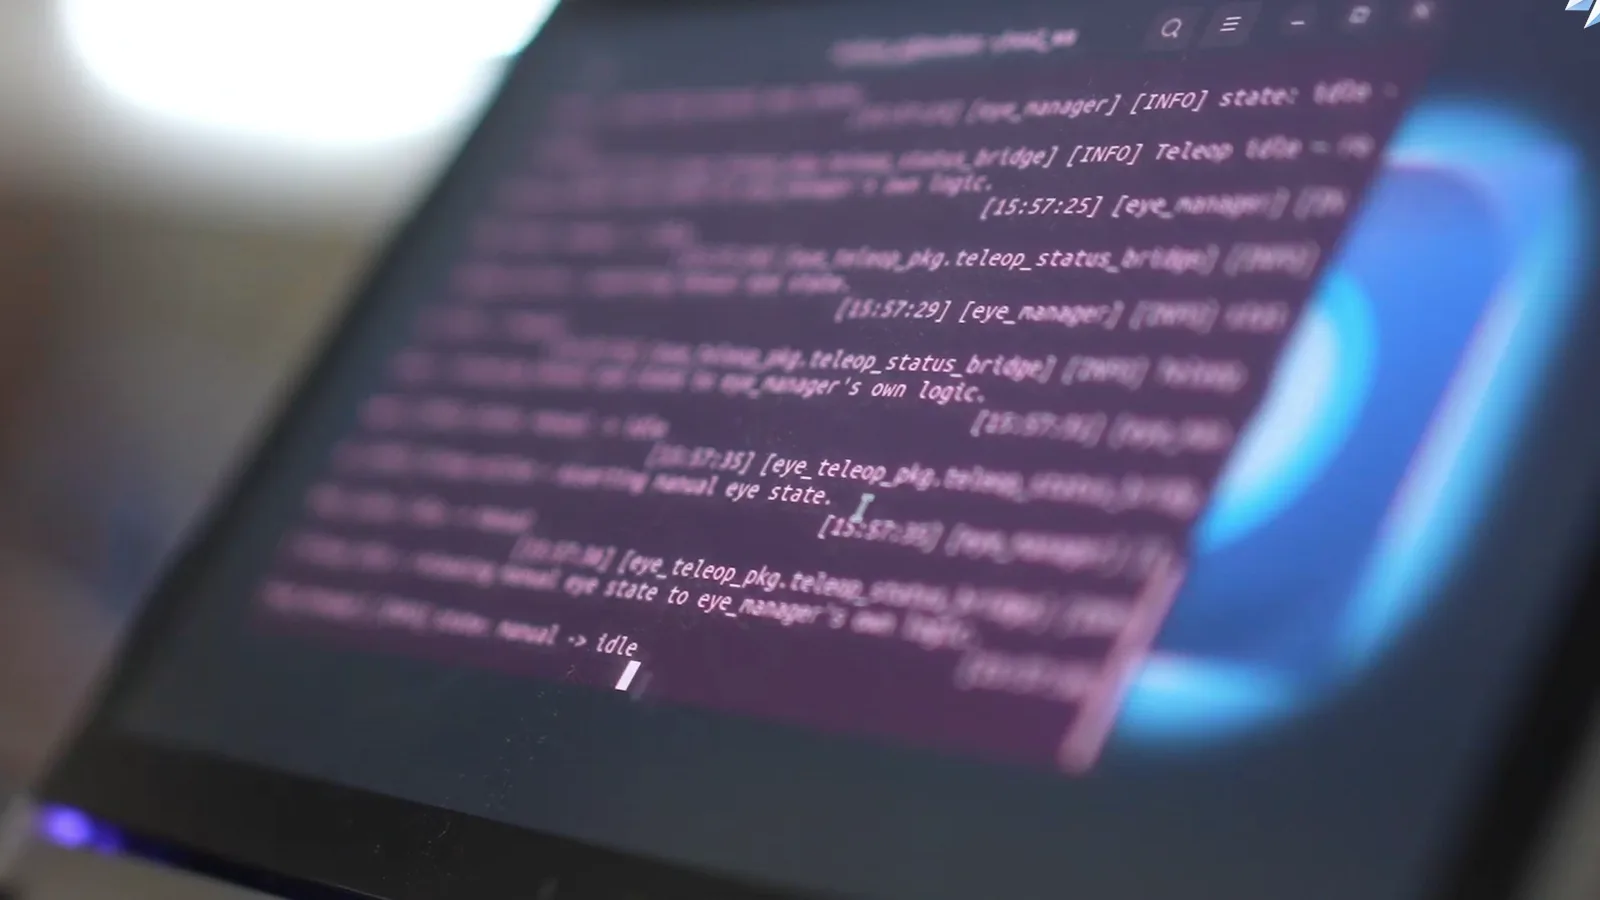
ORBIT runs its software stack on an onboard Ubuntu Linux computer, with live system logs used throughout development.
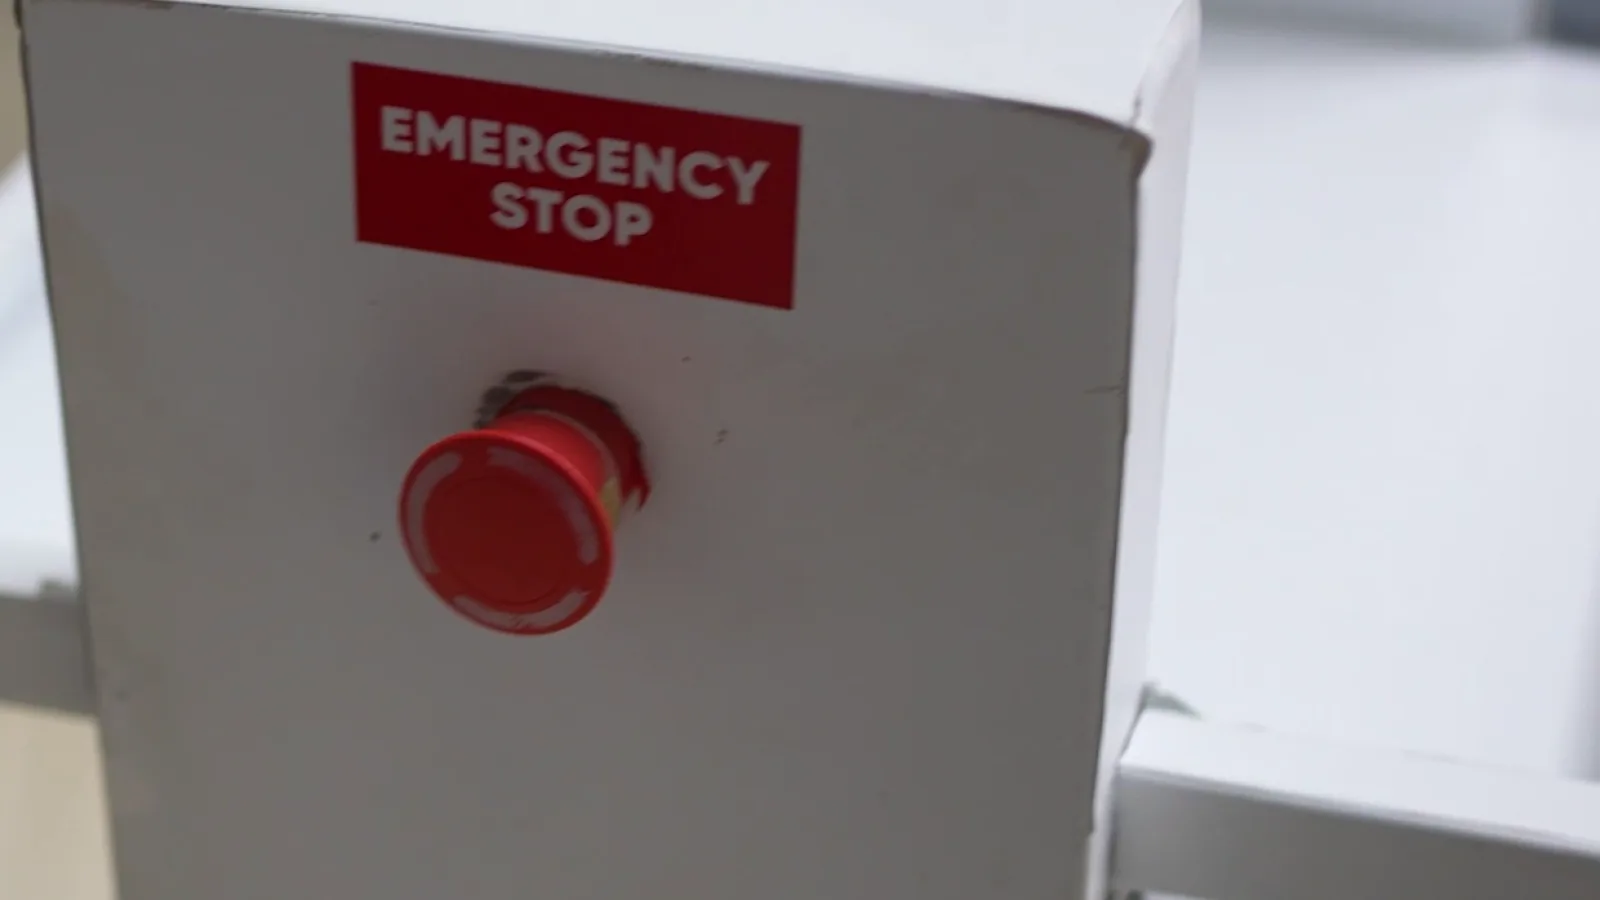
A physical emergency stop is built into the robot's column, within easy reach of staff and guests.
Extending mobile-robot capability toward industrial environments and material-movement workflows.
Hands-on platforms that teach robotics through building and experimentation.
Investigating water-based autonomous systems that can help remove surface waste from lakes.
TEngineering Stack
Our robots are engineered end to end — from mechanical structure to the software that drives them.
Chassis, drive base and service structures designed and built in-house.
Onboard Linux compute, displays, lighting and safety circuits integrated into the robot.
Navigation, behaviour and interface software developed and tested on the physical robot.
Prototypes evaluated in the real environments they are designed for.
Autonomous Robotics. Real-World Impact.